Haebeom Jung
Ph.D. Student
Graduate School in AI
Seoul National University
haebeom.jung [at] snu [dot] ac [dot] kr
Current Affiliations
- Robotics
- 3D reconstruction

I am an Integrated Ph.D. student in the Graduate School in AI at Seoul National University, advised by Jaesik Park. My research spans robotics and 3D reconstruction: I currently focus on robot manipulation, and I also work on SLAM and sensor calibration such as targetless LiDAR–camera calibration. Before graduate school I worked as a robotics software engineer on SLAM and autonomous navigation.
I worked at Kakao Mobility (2021–2022) as a robotics software engineer. I built the data-collection software for the self-driving fleet and worked on visual SLAM and localization. Before that I completed my military service at Stryx (2019–2021) as a lead software engineer, where I developed sensor-capture software for mobile mapping systems and an autonomous driving stack for unmanned ground vehicles covering SLAM, localization, sensor fusion, and path planning. I also interned at ROBOTIS in 2019 and tested the Open Manipulator before its open-source release.
I received my B.S. in Robotics from Kwangwoon University. I was a member of the humanoid division of RO:BIT, the university's robot game team, for three years and led it in 2018. We won awards at RoboCup and national competitions, and I received a full scholarship for it.
I serve as a reviewer for NeurIPS, ECCV, CVPR, and IEEE TIP.
Latest news
All news →-
NEW! Our paper, Distractor-Aware COLMAP-Free 3D Gaussian Splatting, has been accepted to WACV 2027.
-
BeyondCSe, our work on event-referential grasping with active view selection, is now available on arXiv.
-
Rest2Art, our work on articulated object reconstruction, has been accepted to ECCV 2026.
-
I was selected as a Jeongheon Foundation Scholar for my Ph.D. studies.
Publications
All publications →-
arXiv 2026 arXiv preprint
Beyond the Current Scene: Event-Referential Grasping with Active View Selection
@article{lee2026beyondcse, title = {Beyond the Current Scene: Event-Referential Grasping with Active View Selection}, author = {Lee, Hyunjoon and Jung, Haebeom and Cha, Eunsung and Lee, Daeun and Wang, Yu-Chiang Frank and Choe, Jaesung and Park, Jaesik}, journal = {arXiv preprint arXiv:2609.39375}, year = {2026} } -
WACV 2027 IEEE/CVF Winter Conference on Applications of Computer Vision
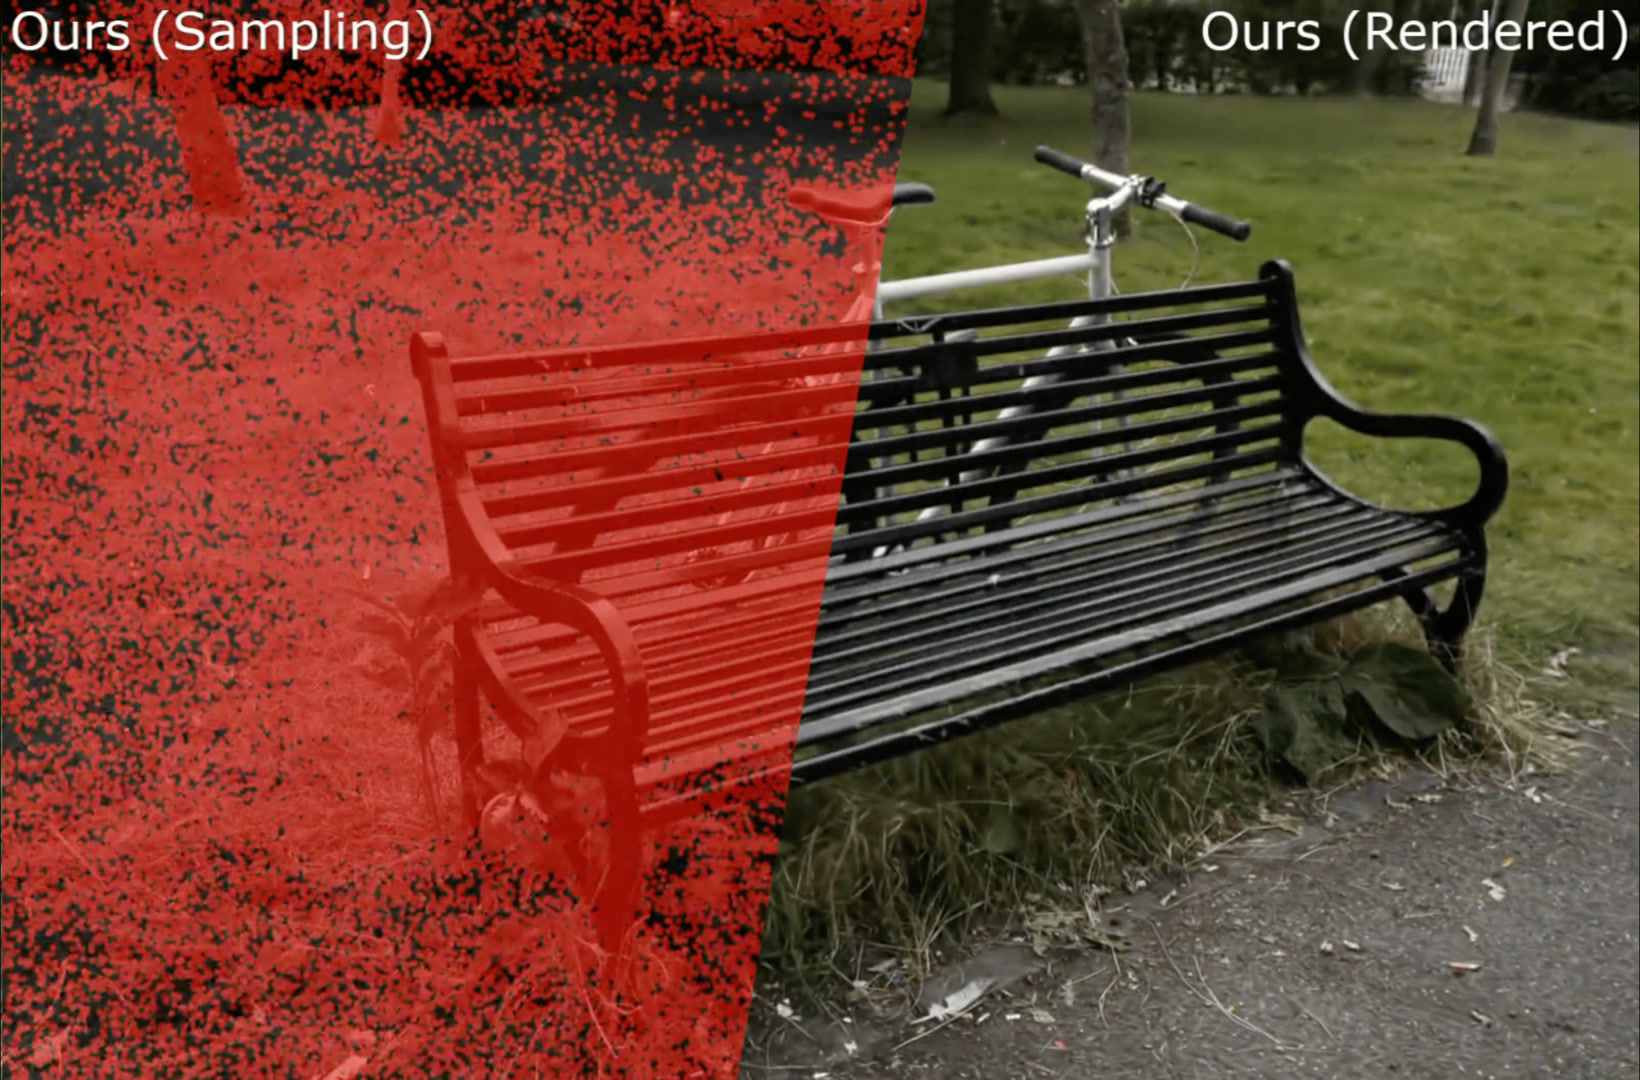
Distractor-Aware COLMAP-Free 3D Gaussian Splatting
@inproceedings{kim2027distractor, title = {Distractor-Aware COLMAP-Free 3D Gaussian Splatting}, author = {Kim, Namtae and Jung, Haebeom and Park, Jaesik}, booktitle = {IEEE/CVF Winter Conference on Applications of Computer Vision (WACV)}, year = {2027} } -
ECCV 2026 European Conference on Computer Vision
Articulated Object Reconstruction from Rest-State Observation
@inproceedings{lee2026articulated, title = {Articulated Object Reconstruction from Rest-State Observation}, author = {Lee, Daeun and Lee, Jaeah and Kim, Woosung and Jung, Haebeom and Park, Jaesik}, booktitle = {European Conference on Computer Vision (ECCV)}, year = {2026} } -
RA-L 2026ICRA 2026 IEEE Robotics and Automation Letters, vol. 11, no. 4
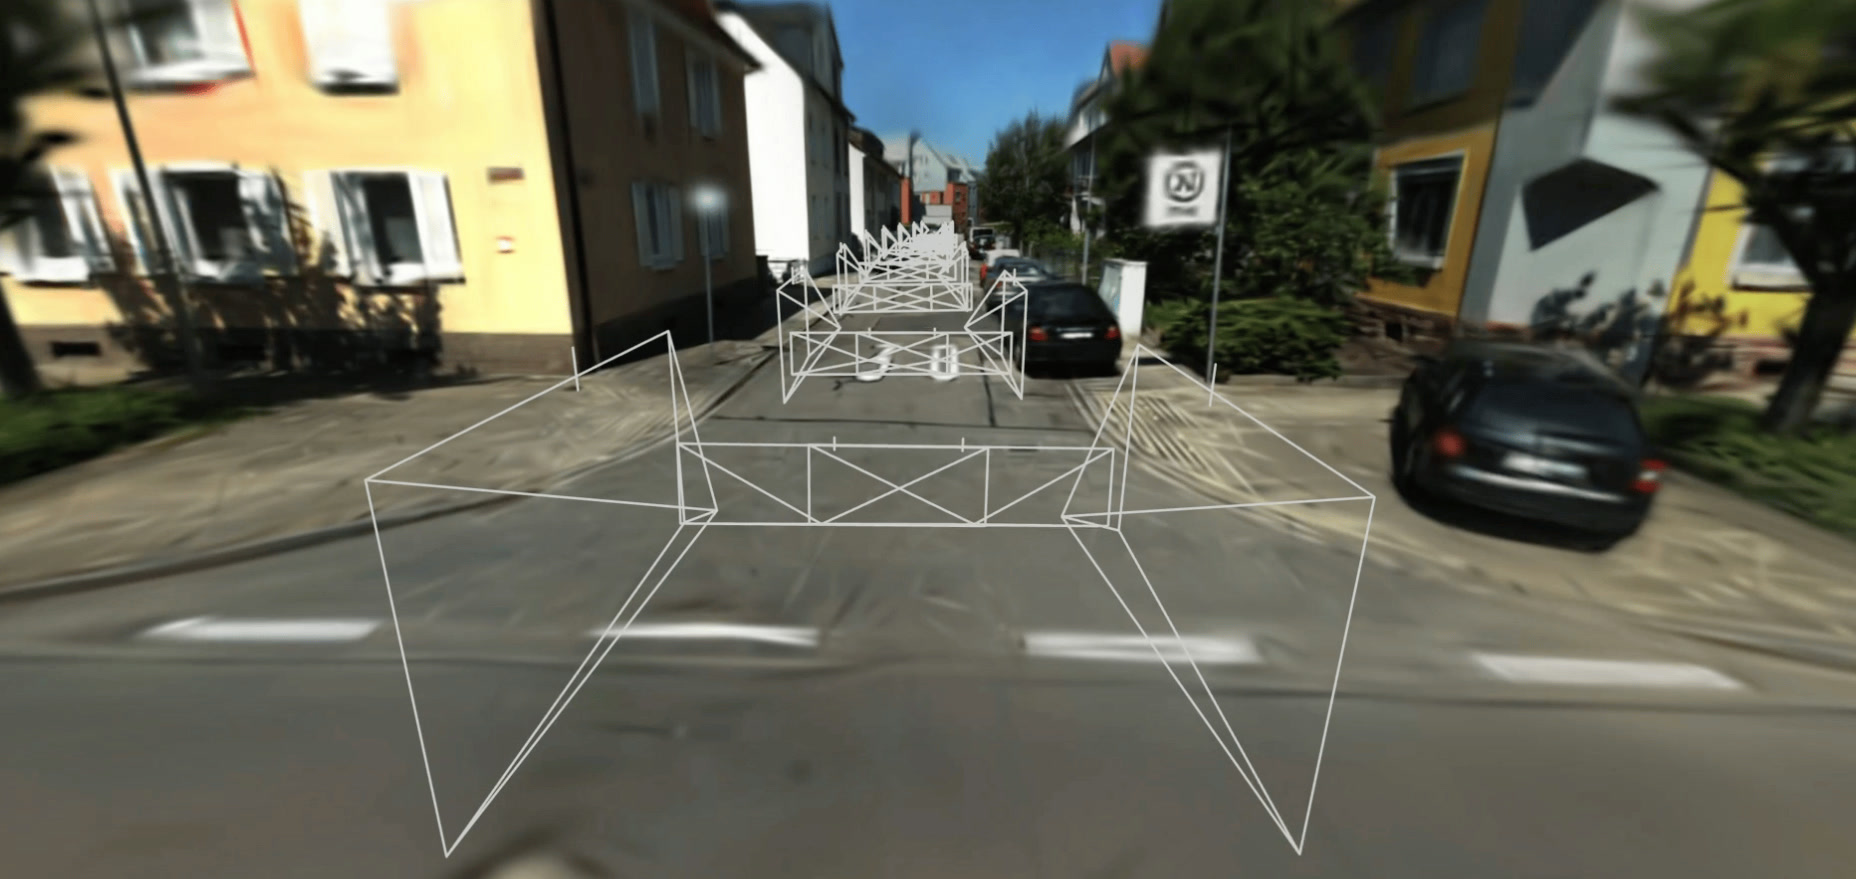
Targetless LiDAR-Camera Calibration with Neural Gaussian Splatting
@article{jung2026targetless, title = {Targetless LiDAR-Camera Calibration with Neural Gaussian Splatting}, author = {Jung, Haebeom and Kim, Namtae and Kim, Jungwoo and Park, Jaesik}, journal = {IEEE Robotics and Automation Letters}, volume = {11}, number = {4}, pages = {4777--4784}, year = {2026}, doi = {10.1109/LRA.2026.3665066} } -
NeurIPS 2025 Advances in Neural Information Processing Systems, vol. 38
Metropolis-Hastings Sampling for 3D Gaussian Reconstruction
@inproceedings{kim2025metropolis,
  title     = {Metropolis-Hastings Sampling for 3D Gaussian Reconstruction},
  author    = {Kim, Hyunjin and Jung, Haebeom and Park, Jaesik},
  booktitle = {Advances in Neural Information Processing Systems (NeurIPS)},
  volume    = {38},
  pages     = {142862--142887},
  year      = {2025}
}


Vitæ
Full CV →-
-
 Seoul National University Sep. 2023 – Present
Ph.D. Student in Artificial Intelligence
SNU Visual & Geometric Intelligence Lab · Advisor: Jaesik Park
-
 Kakao Mobility Jul. 2021 – Apr. 2022
Software / Robotics Engineer
Self-driving data collection · visual SLAM and localization
-
 Stryx Dec. 2019 – Jul. 2021
Software / Robotics Engineer · compulsory military service
MMS sensor capture · UGV autonomous driving (SLAM, localization, sensor fusion, planning)
-
 ROBOTIS Jan. 2019 – Feb. 2019
Robotics Engineer
Open Manipulator verification and examples
-
 KwangWoon University Mar. 2016 – Feb. 2023
B.S. in Division of Robotics
Full scholarship · RO:BIT humanoid team leader (2018)
Selected honors
All honors →-
Jeongheon Foundation Ph.D. Scholarship
-
SNU AI Fellowship (M.S. Program)